NexArm robotic arm by Hiwonder
Hiwonder's NexArm is a next-generation Embodied AI robotic arm designed for rapid validation of imitation learning and reinforcement learning. With direct compatibility with Hugging Face LeRobot, it allows models to be deployed without laborious hardware troubleshooting.
Compared with SO-ARM101
NexArm uses a dual-processor ESP32 + AT32 architecture, features an all-metal construction, a larger working radius, a rotating base and a parallel-rail gripper. It supports multiple control methods straight out of the box. This makes it a refined engineering platform for Embodied AI projects.
A Closer Look at NexArm
Industrial precision and exceptionally smooth movement
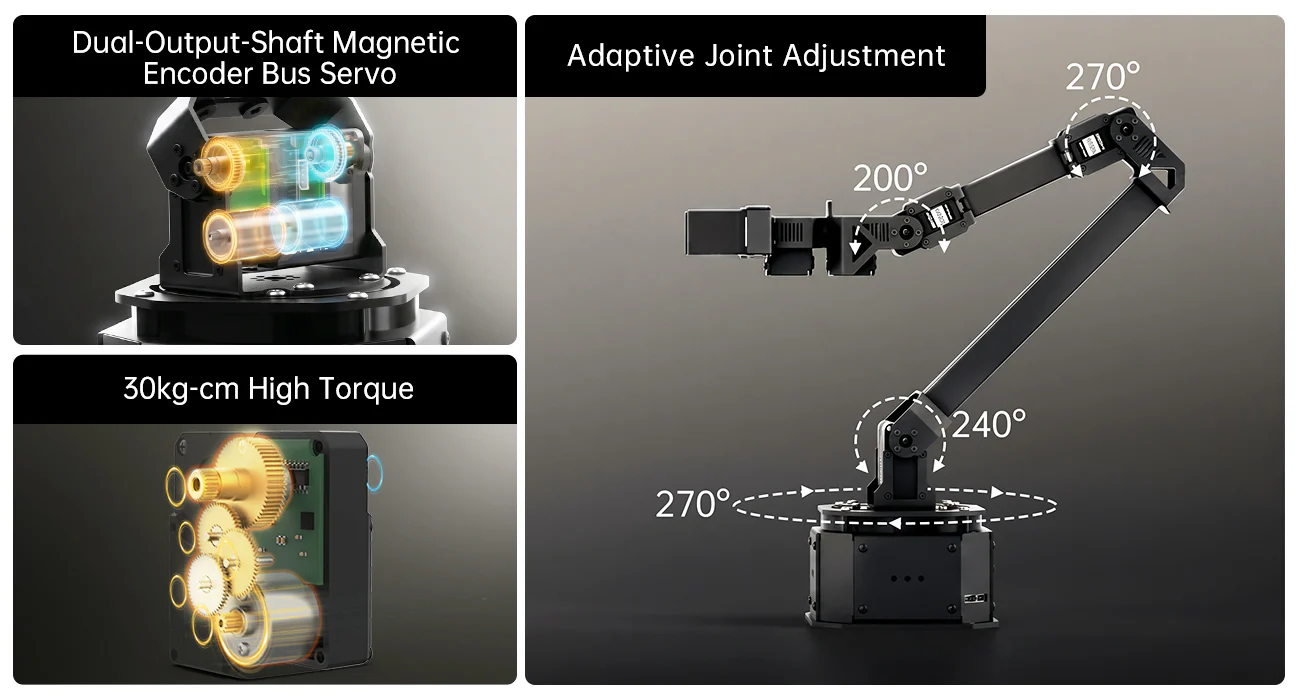
Algorithm accuracy means nothing if the hardware suffers from irregular joint vibrations. NexArm has an all-metal construction powered by precision bus servos with 65 kg·cm magnetic encoder servos, providing repeatability of ±2 mm. Combined with advanced inverse kinematics algorithms and curve smoothing, the arm natively calculates complex trajectories, minimizing vibrations during start and stop, resulting in smooth, natural movement.
Easy Imitation Learning — Leader-Follower Mode
Forget manual coding or delayed pipelines that undermine dataset quality. Thanks to its specialized dual-processor ESP32 + AT32 hardware synchronization architecture, NexArm enables millisecond-level motion tracking between the leader and follower arms. This hardware-synchronized structure delivers clean real-time data directly to Hugging Face LeRobot, accelerating the training of control policies like never before.
Modern 6 TOPS Computing System and Multimodal AI Interaction
NexArm allows advanced vision processes to run directly on the arm, without requiring a PC. Equipped with a 6 TOPS K230 vision module, the arm integrates perception directly on the device, offering substantial edge computing power. This enables multimodal large AI models and more than 30 advanced functions—such as YOLO tracking or hand-eye coordinated grasping—to be deployed directly on a desktop.
20.06.2026
Source: Hiwonder
NexArm, Hiwonder, robotic arm, robotic arm, Embodied AI, AI robotics, AI robotics, Hugging Face LeRobot, LeRobot, imitation learning, imitation learning, reinforcement learning, reinforcement learning, leader-follower mode, leader-follower mode, robot arm for AI research, educational robotics, research robotics,ESP32, AT32, dual-chip architecture, dual-processor architecture, magnetic encoder servos, magnetic encoder servos, bus servos, 65 kg·cm servo, all-metal robotic arm, metal robotic arm, rotating base, rotating base, parallel-rail gripper, parallel gripper, ±2 mm repeatability, inverse kinematics, inverse kinematics, smooth motion control, K230 vision module, 6 TOPS AI module, edge AI, edge computing, computer vision, machine vision, YOLO tracking, object tracking, hand-eye coordination, hand-eye coordinated grasping, multimodal AI, AI perception, autonomous grasping, vision-guided robotics